Overview
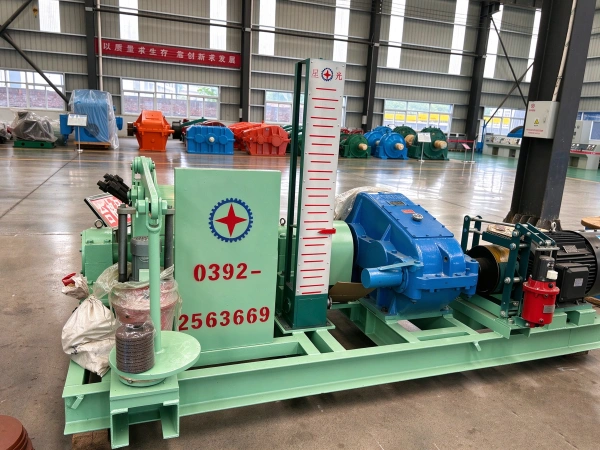
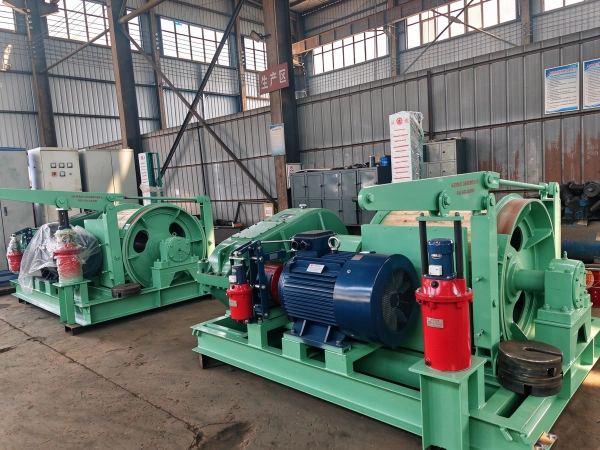
The JTK series of mining hoisting winches are core material-handling devices specifically designed for small and medium-sized mines. They are widely used for lifting materials and transporting personnel in inclined roadways in coal mines, metal mines, and non-metallic mines; they may also serve as lifting equipment for small vertical shafts or as surface auxiliary traction devices. This product series complies with the *Safety Inspection Specification for JTK-type Hoisting Winches for Coal Mines* (AQ/T 1032-2007) and holds mining safety certifications such as MA and KA; certain explosion-proof models (e.g., the JTKB series) are suitable for hazardous environments containing coal dust and methane.
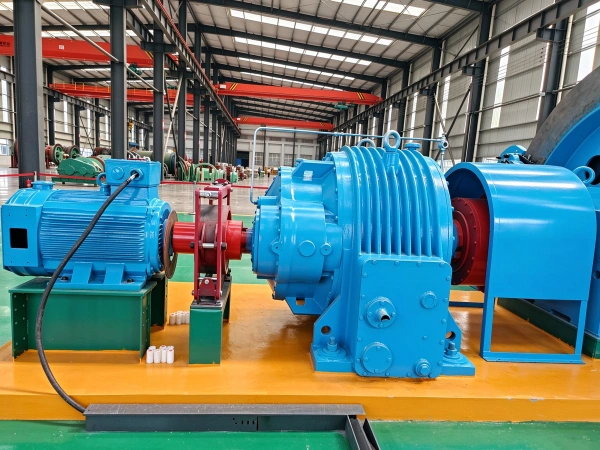
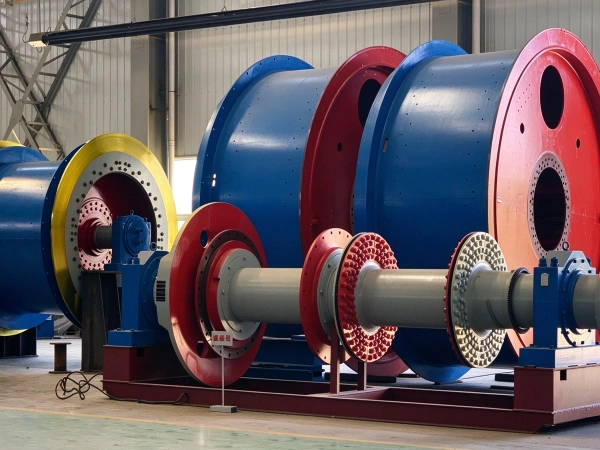
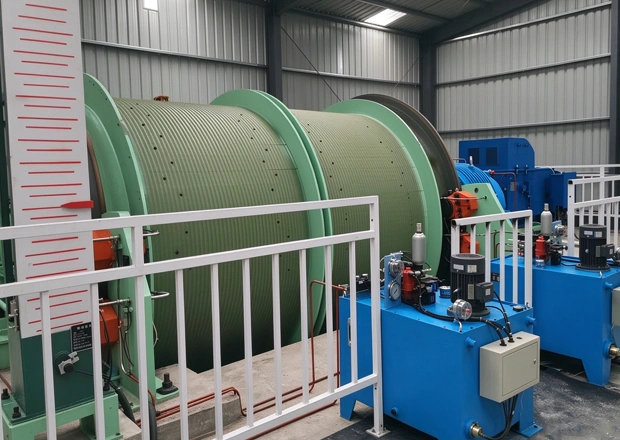
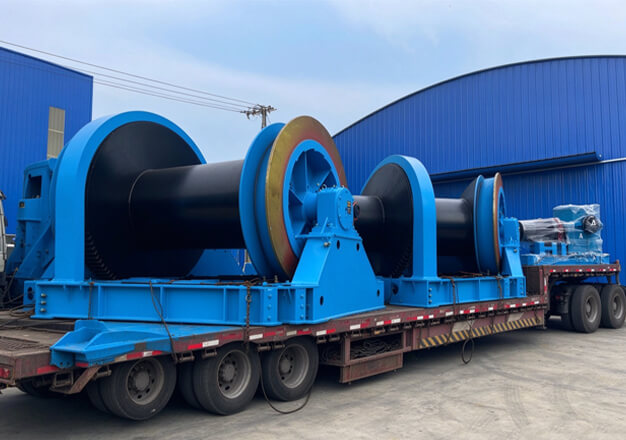
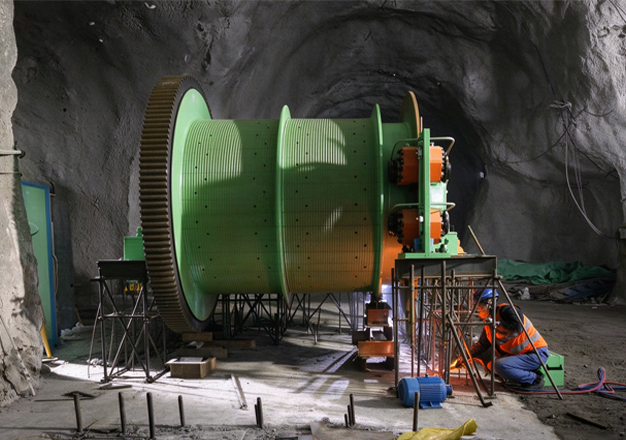
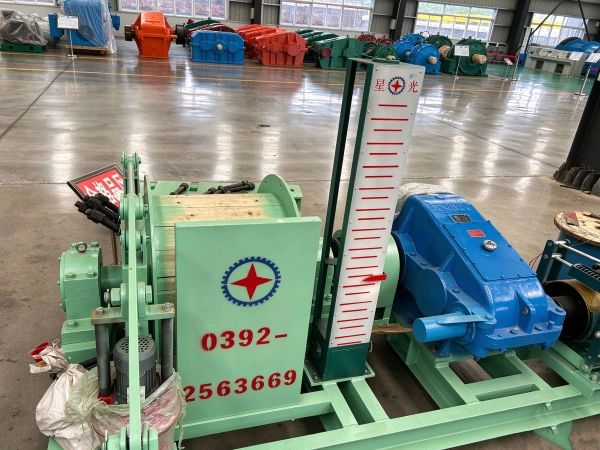
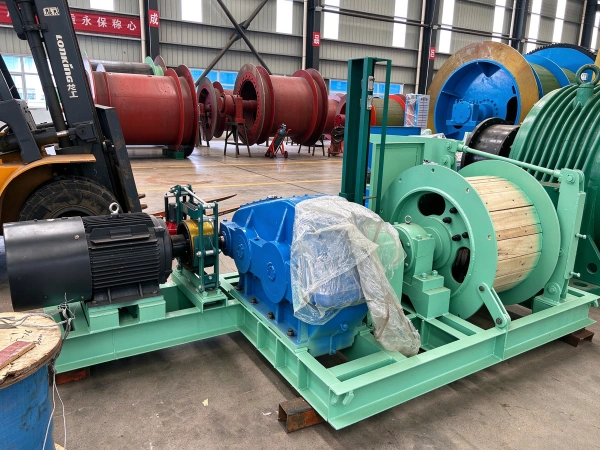
The winch features a modular design and primarily consists of a main shaft assembly, a reduction gearbox, a dual braking system, a depth indicator, and an electrical control system; it has a compact structure and is easy to maintain. Its rated static tension ranges from 15–40 kN, its drum diameter covers 0.8–1.6 m, and its rope capacity can reach 504 m (with three-layer winding). It can be paired with asynchronous motors of various power ratings, from 37 kW to 155 kW, thereby meeting the diverse operational requirements of inclined shafts with inclinations ≤ 28° or small vertical shafts.
Core Structure and Design Features
The drum shell adopts an integral or split-type drum design and is manufactured from high-strength low-alloy steel Q345A; its surface is grooved with helical rope grooves to reduce wear on the steel wire rope.
Adjustable double-row roller bearings are installed at both ends of the spindle, enabling full rolling transmission and achieving an overall efficiency of ≥90%.
Block braking (hydraulic actuation or resistance-speed regulation), equipped with a service brake and a heavy-duty hammer-type safety brake, supporting secondary braking and manual rope-adjustable clutch;
The hydraulic station drive system has a short response time and can automatically brake when power is lost.
Either a planetary gear reducer or a cylindrical gear reducer may be selected, providing smooth transmission and low noise levels;
This control method supports resistance-based speed regulation or frequency conversion speed regulation, achieving energy savings of over 30% and delivering excellent performance during low-speed, heavy-load starts.
Security Protection Features
Application Scenarios and Limitations
Principle
The JTK mining winch raises and lowers materials through a power transmission path consisting of “motor–reduction gearbox–drum–steel wire rope”; the specific process is as follows:
The asynchronous motor (e.g., the YR series) transfers torque to the reduction gearbox via a gear coupling; after three-stage cylindrical gear reduction, the rotational speed and torque are adjusted;
The output shaft of the reduction gearbox directly drives the drum to rotate; the rope grooves on the drum surface (protected by wooden liners) guide the steel wire rope into orderly winding, converting the rotational motion into the linear pulling motion of the steel wire rope;
A dual-system configuration comprising a service brake (standard brake) and a safety brake (emergency brake) is employed. The service brake provides conventional deceleration and stopping through manual operation; the safety brake automatically applies the brake when power is lost or a limit is exceeded. The braking torque is ≥3 times the maximum static torque, ensuring an emergency braking response time ≤0.6s;
The depth indicator provides real-time display of the hoisting position; together with over-lift protection (triggered at 0.5 m beyond the limit), over-speed protection (activates when the speed exceeds the rated speed by 15%), and rope-release protection, it forms a closed-loop safety control system.
Parameter
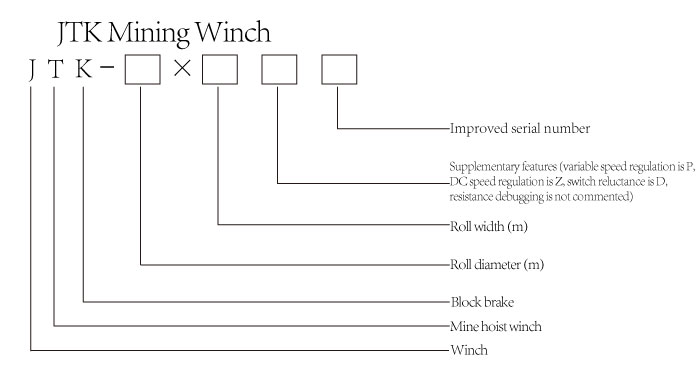
| technical parameter | ||||||||
| model | drum | Maximum static tensile force of the steel wire rope: kN | Maximum diameter of steel wire rope, mm | Maximum accelerationm/s | Number of windings | Maximum elevation gain or slopelongm | ||
| number | diameter m | widthm | ||||||
| JTK-0.8×0.6 | 1 | 0.8 | 0.6 | 15 | 15 | 1.5 | 3 | |
| JTK-1×0.8 | 1 | 1 | 0.8 | 15 | 15 | 1.8 | 3 | 426 |
| JTK-1.2×1 | 1 | 1.2 | 1 | 30 | 20 | 2.6 | 3 | 472 |
| JTK-1.2×1.2 | 1 | 1.2 | 1.2 | 30 | 20 | 2.6 | 3 | 582 |
| JTK-1.4×1.2 | 1 | 1.4 | 1.2 | 35 | 22 | 2.6 | 3 | 617 |
| JTK-1.6×1.2 | 1 | 1.6 | 1.2 | 45 | 26 | 4.1 | 3 | 601 |
| JTK1.6×1.5 | 1 | 1.6 | 1.5 | 45 | 26 | 4.1 | 3 | 767 |